
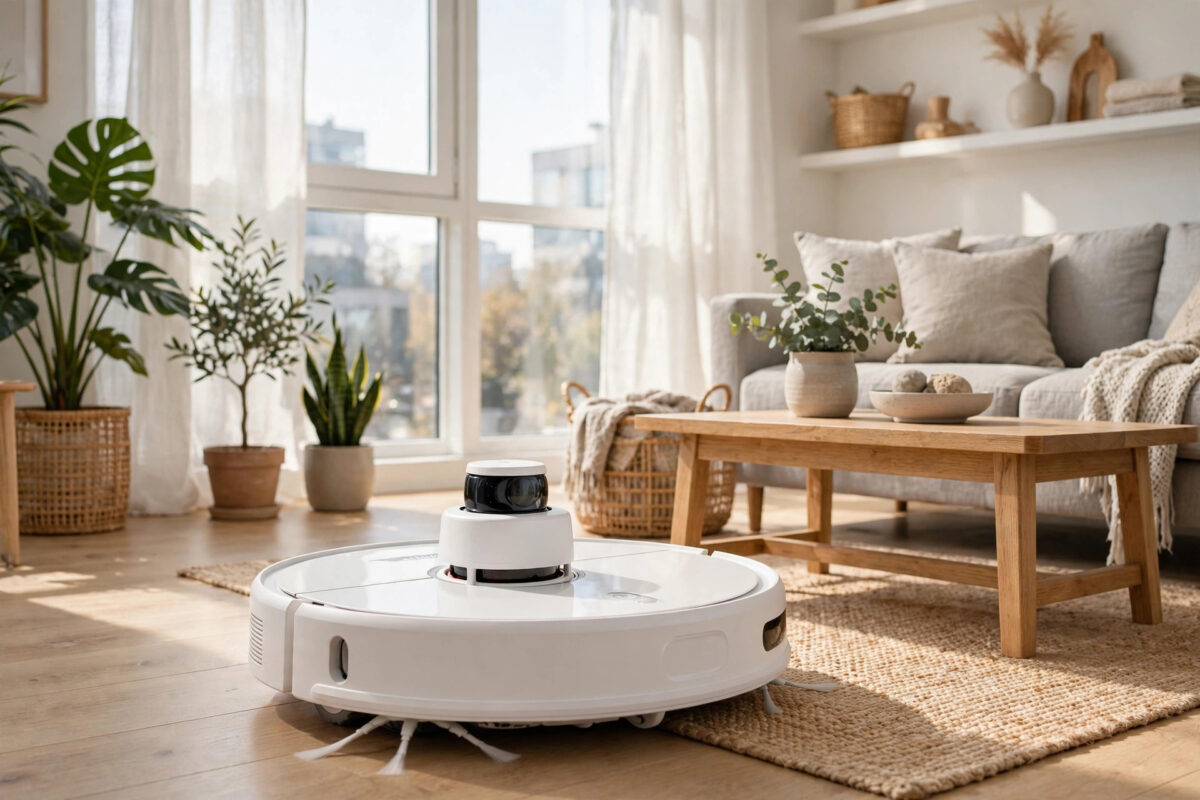
Your Roborock S7 once knew your home perfectly. Now it forgets the map, splits one bedroom into two, or adds a mystery room that does not exist. You redraw, it forgets again. Map problems are frustrating because the robot still cleans well, it just no longer knows where it is cleaning.
The cause is usually positioning, not a broken sensor. The S7 builds its map with its LiDAR turret and wheel movement, and it needs a stable start point and clear landmarks to match each new clean to the saved map. Fix the start, clean up the map settings, and the duplicates stop.
Quick Answer
Always start cleans from the dock, turn on multi-level map saving in the app, restore your best saved map, then merge or split the rooms correctly and save again. Remove mirrors and moved furniture that confuse positioning, and never carry the robot to another room mid-clean. If the map still corrupts, delete it and remap the home in one full, uninterrupted run from the dock.
Why the S7 Loses Maps and Creates Duplicate Rooms
The S7 spins a laser in its top turret to measure walls and doorways. Each clean, it compares what it sees with the saved map. If the match is weak, the app may create a new map or overlap a second copy of a room on top of the first. That overlap is what you see as duplicate rooms.
Weak matches happen for simple reasons. The dock was moved, even a little. The robot was lifted and placed in a room by hand. Big furniture moved, such as a sofa or a bed. Curtains, mirrors, or glass doors confused the laser. Or the robot started a clean from a random spot after a spot clean, and saved that view as a new floor.
There is also a settings trap. If map saving or multi-level maps are off, the S7 treats each clean as temporary. It may show a nice map during the clean and then throw it away, which feels exactly like losing the map.
Step 1: Fix the Dock and Starting Routine
Good maps start at the dock. Make the dock a fixed landmark the robot can always trust.
- Place the dock against a straight wall on a hard floor, with clear space on both sides and in front.
- Do not move the dock after mapping. Even a small shift can break the map match.
- Always start full cleans from the dock, never by carrying the robot to a room.
- If you lift the robot during a clean, return it to the exact spot you picked it up from, or send it back to the dock.
- Keep the dock area free of shoes, bags, and charging cables that change shape between cleans.
- Clean the LiDAR turret window and the cliff and wall sensors with a soft dry cloth.
This routine matters more than any app setting. For a wider view of how the two big robot brands handle mapping, see our comparison of Roborock and Roomba vacuums, because each brand recovers from lost positioning in a different way.
Step 2: Turn On Map Saving and Restore the Best Map
Next, check the app settings and bring back the last good map instead of starting from zero.
- Open the Roborock or Mi Home app and open your S7.
- Go to Settings and find Map Management or Multi-Level Map.
- Turn on map saving and, if your home has more than one floor, turn on multi-level maps.
- Open the map list. You should see your saved floor maps with dates.
- Select the newest map that looks correct and choose Restore or Use This Map.
- Delete any corrupted copies showing doubled rooms, so the robot cannot load them again.
- Send the robot to the dock, then start a short clean to confirm it positions itself correctly on the restored map.
When the robot positions correctly, its icon sits on the dock on the map and room colours match your real rooms. If the icon appears in a wall or in the wrong room, positioning has failed again and you should dock it and retry before cleaning.
Step 3: Merge, Split, and Name Rooms Correctly
Some duplicates are not a second map. They are one room split into two by a doorway line drawn in the wrong place, or two real rooms merged into one. Fix the room layout once, properly.
- Open the map editor and choose Edit Room or Divide Rooms.
- To fix a room split in two, select both parts and use Merge.
- To split a merged space, use Divide and draw the line along the real doorway or wall.
- Check narrow areas such as hallways and bathrooms, where wrong lines are most common.
- Rename each room with a clear name you will use in schedules and voice commands.
- Save the map and wait for the app to confirm the save before closing it.
After editing, run one full clean and check the map again. Small line errors often show only after the robot has driven the edges. Correct them once more and save. Two careful edits beat five rushed ones.
Step 4: Remove the Things That Confuse the Laser
If maps keep corrupting in the same place, something in that place is fooling the sensor. Walk the home with the robot’s view in mind.
- Mirrors and full-height glass: the laser sees a room beyond the glass. Add a no-go zone over the glass area or cover the lower part during mapping.
- Moved furniture: map on a normal day, with sofas, beds, and tables in their usual places.
- Long curtains to the floor: the robot sees a soft, moving wall. Tie them up for the mapping run.
- Very dark or shiny floors: clean the cliff sensors and add good light during mapping.
- Clutter piles: boxes and laundry baskets become fake walls. Clear the floor before a mapping run.
Use invisible walls or no-go zones for problem spots you cannot change, such as a mirror wardrobe. Once the zone is saved, the robot stops trying to map the false room behind the glass.
Step 5: Remap From Scratch When the Map Is Too Damaged
If restoring and editing do not hold, a clean remap is faster than more repairs.
- Delete the broken maps for that floor in Map Management.
- Dock the robot and make sure it is well charged.
- Tidy the whole floor, open all doors you want mapped, and lift cables and small items.
- Start a full clean from the dock and let it finish without pausing or moving the robot.
- When the map appears, edit rooms, name them, set no-go zones, and save at once.
- Run a second normal clean the next day to confirm the map loads and stays stable.
For the exact menu names in the current app version, check Roborock’s official support pages, because Roborock moves map settings between app updates.
Mistakes to Avoid
- Moving the dock to a nicer corner after mapping. The dock is the map anchor. Moving it breaks everything.
- Carrying the robot to a messy room. Use room cleaning in the app instead, so positioning stays correct.
- Saving every temporary map. Spot cleans create odd partial maps. Keep only full, clean floor maps.
- Editing the map during a clean. Wait until the robot is docked, then edit and save.
- Ignoring a dirty LiDAR window. A dusty turret gives weak readings and ghost rooms.
- Mapping with doors half open. Door positions change the map shape. Decide, then map with doors fully open or closed.
Conclusion
A Roborock S7 that loses its map or invents duplicate rooms is struggling to match what it sees with what it saved. Give it a fixed dock, always start from the dock, restore the best saved map, and fix room lines in the editor. Remove mirrors and clutter that fool the laser, and remap once, cleanly, if the old map is too damaged to trust.
Frequently Asked Questions
Why does my Roborock S7 create a new map instead of using the saved one?
It failed to position itself on the saved map, usually because the dock moved or the robot was started by hand in a room. Start from the dock and make sure map saving is turned on in settings.
How do I merge two rooms that are really one room?
Open the map editor, choose the room edit tool, select both parts of the split room, and use Merge. Save the map, then run a clean to confirm the room stays merged.
Can the S7 remember maps for more than one floor?
Yes, with multi-level maps turned on. Carry the robot to the new floor only at the start, place it down, and let it position or create that floor’s map. Keep the floors saved separately.
Will a factory reset fix my map problems?
It can, but it deletes all maps, schedules, and settings, so use it last. Most map faults are fixed by restoring a saved map, correcting room lines, and fixing the dock position.
Why does a mystery room appear behind my mirror?
The laser reflects off the mirror and measures the reflected space as a real room. Add a no-go zone over the mirror area on the map so the robot ignores that false space.
Leave a Reply